Adaptable movement
- Six-legged movement for uneven-ground research
- Different walking patterns evaluated for stability
Rough-terrain mobility
A six-legged research platform for studying movement across uneven and unpredictable ground.
Novexa explores how a mobile robot can maintain stable movement where conventional flat-floor mobility is less suitable.
Its adaptable legged form supports terrain traversal and inspection research. Discuss your surface conditions, operating space, and intended load with the team to assess suitability.
Choose a view, or enlarge an image for a closer look.
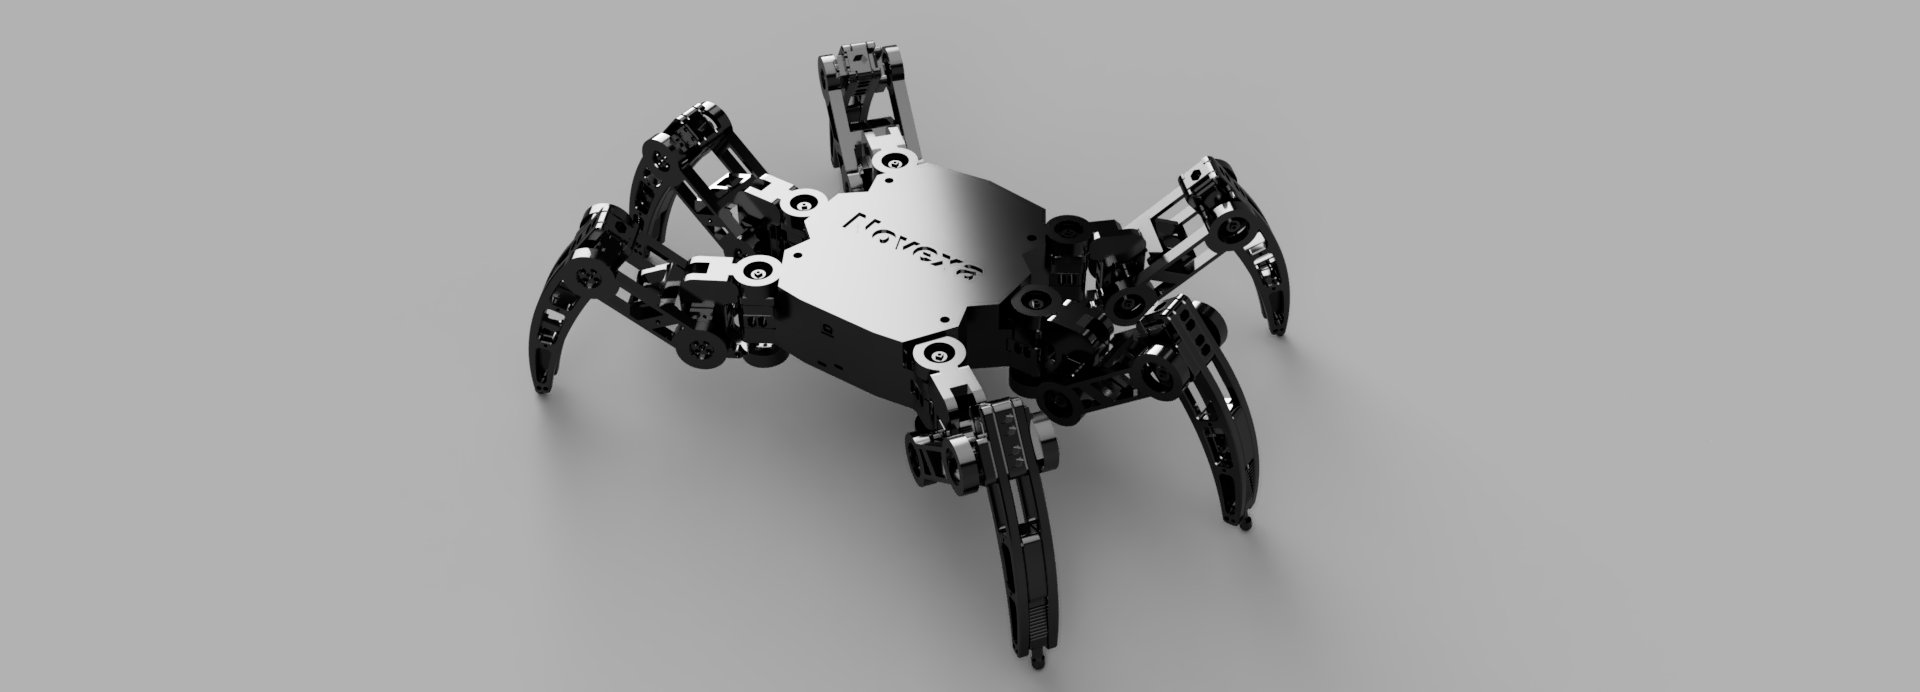
Developed in 2025. Novexa remains an active research platform. Suitability for a specific site, load, or deployment needs to be assessed with the team.
Mechatronic Hexapod Compliance Gaits & Autonomous Navigation
Read the publication ↗Project inquiry
Tell us about the terrain, access constraints, intended payload, and operating environment.
contact@aetheronlabs.in