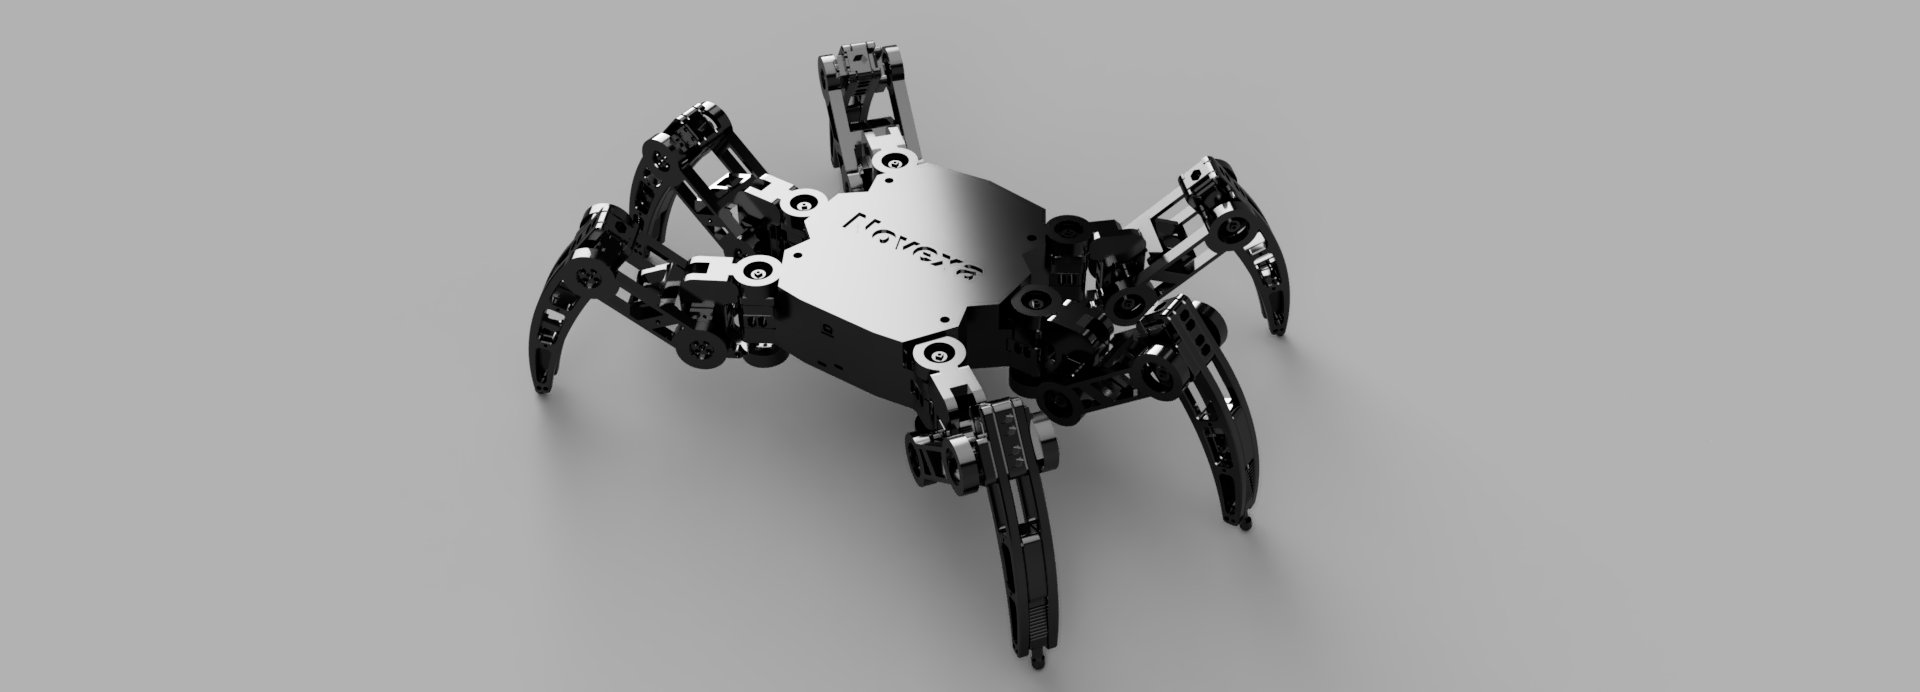
 02 / Legged mobility
Novexa
ActiveA six-legged research platform for studying stable movement across uneven and unpredictable ground.
- Environment
- Uneven terrain
- Mass
- 5.5–6 kg
- Developed
- 2025
 Aetheron Labs
Programs / 01—05
Our primary focus is SLAB for warehouse material movement. Explore the wider portfolio of mobility, inspection, training, and robot-learning projects, each with its own development status.
Compact material handling for warehouse and dark-store workflows. A working remote-operated prototype is informing the next version, with expanded payload, lifting, and tote-handling goals.
*Development targets, subject to testing and validation.
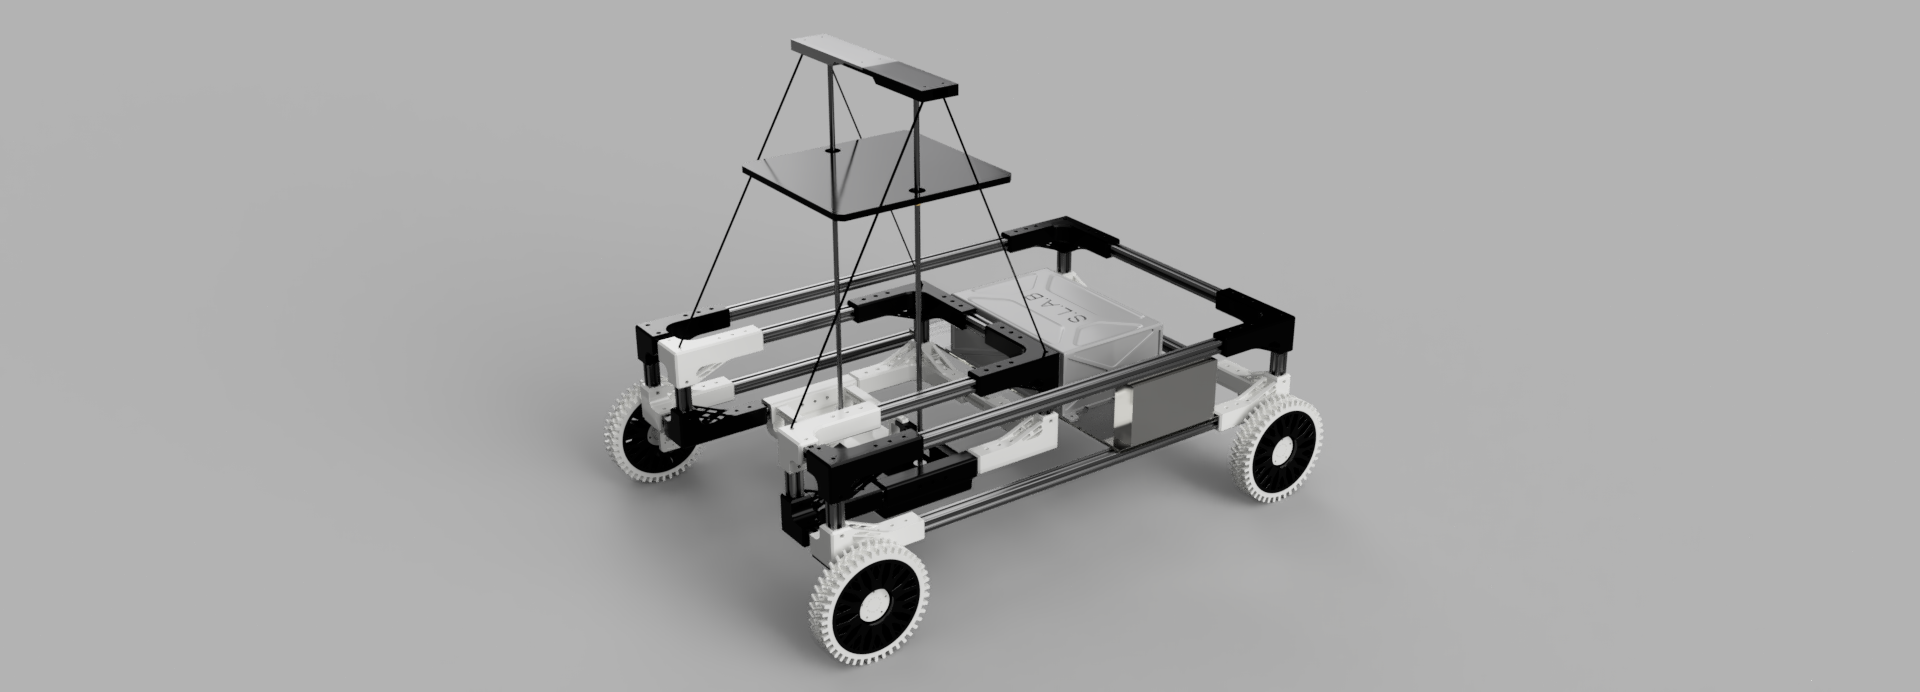 V1 functional POC / V2 in development
Program catalog
Compare intended uses, key details, and development stages. Select a project to discuss your requirements.
02 / Legged mobility
A six-legged research platform for studying stable movement across uneven and unpredictable ground.
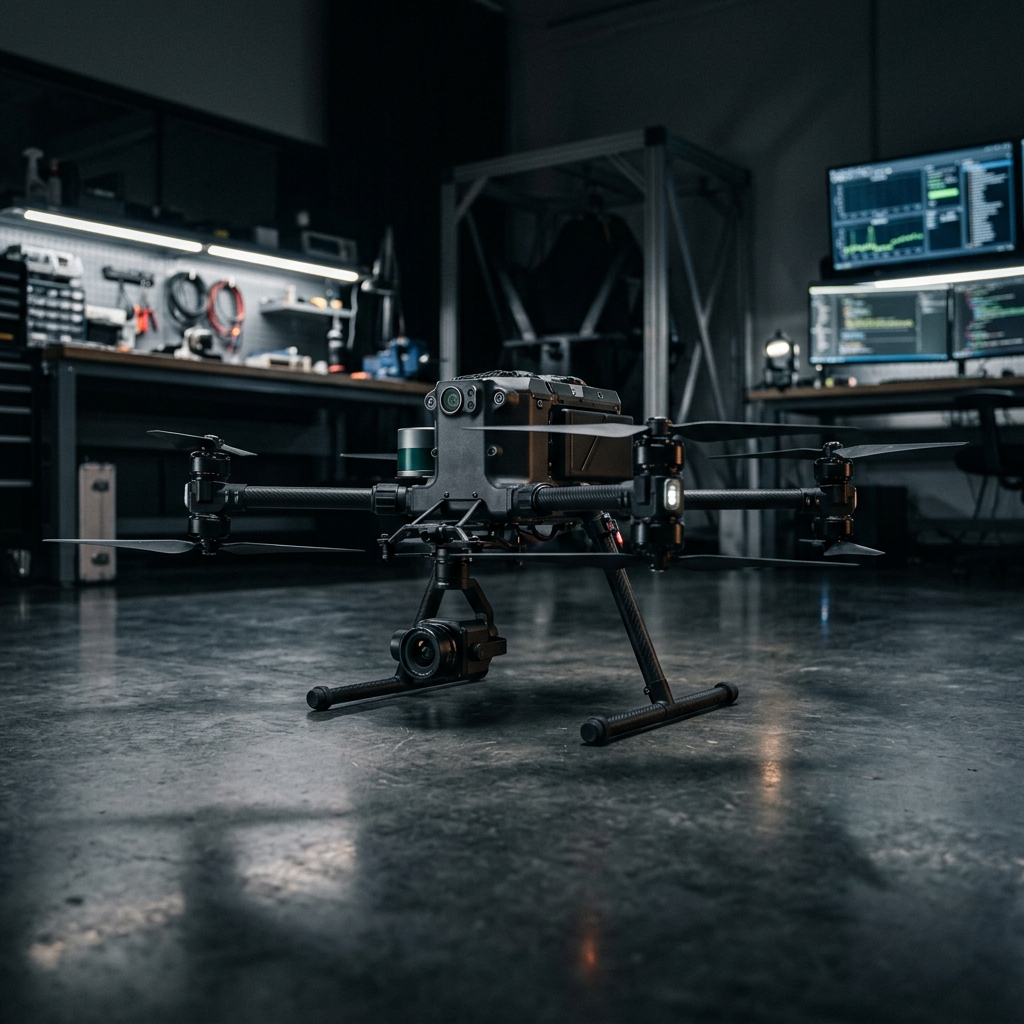 03 / Aerial autonomy
Aerial inspection and mapping research for environments where GPS coverage is limited.
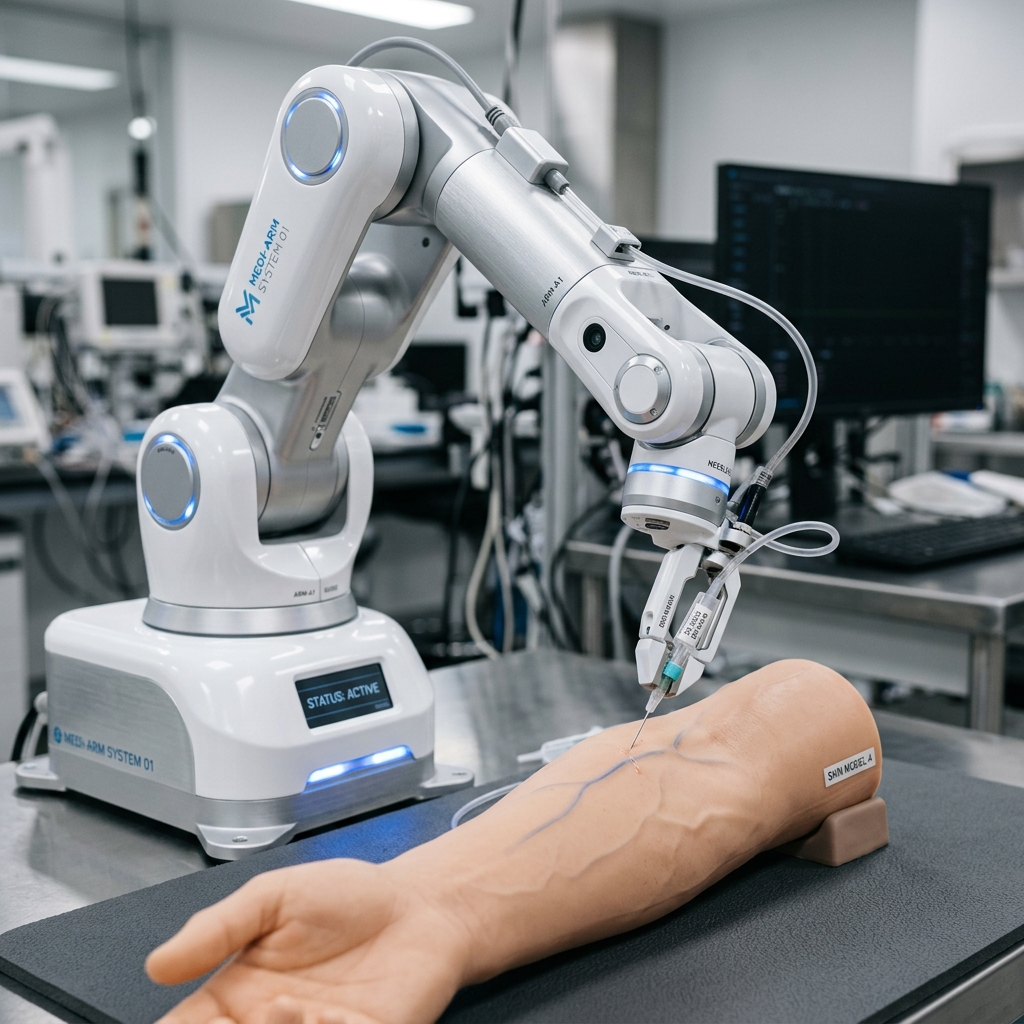 04 / Medical haptics
Medical simulation research focused on needle-insertion practice and measurable tissue resistance.
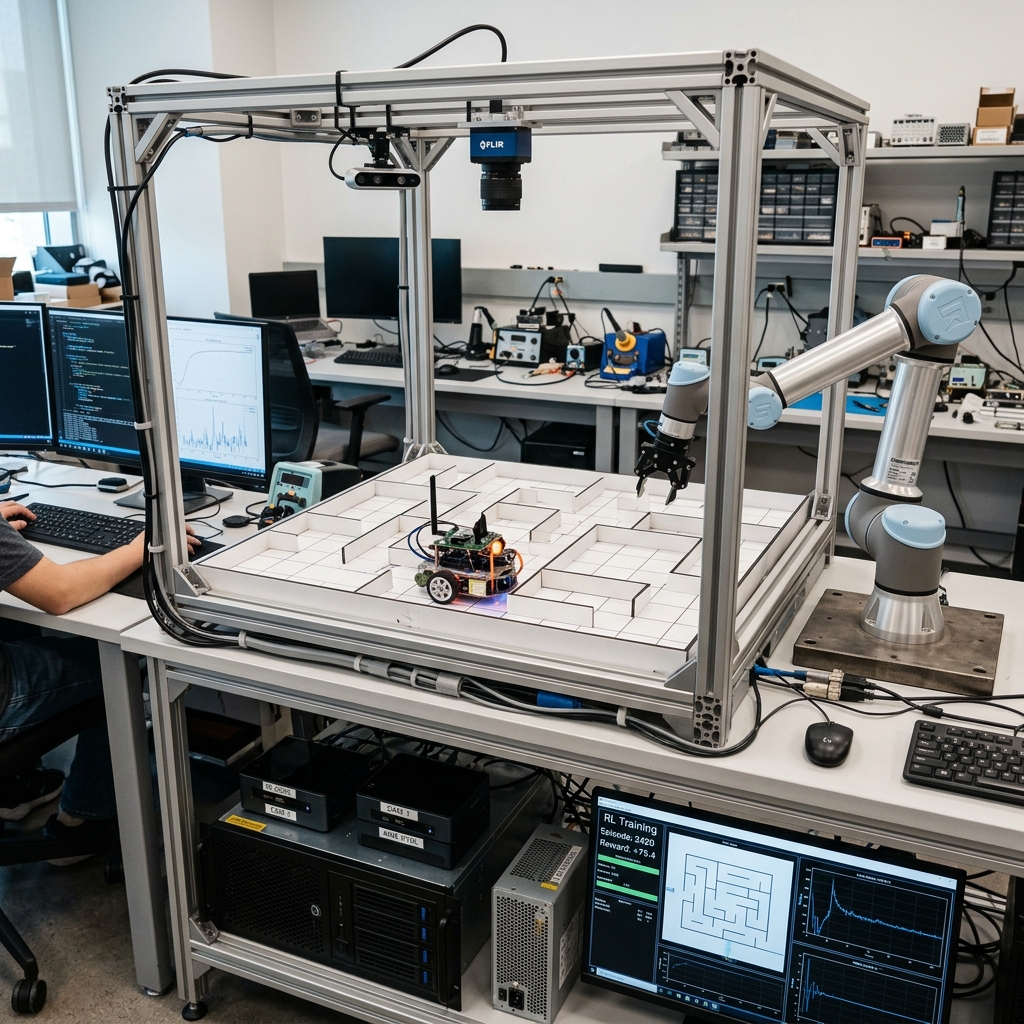 05 / Sim-to-real
A physical research platform for checking how learned movement performs beyond simulation.
Build with us