Current prototype · V1
- Operator-controlled movement from a mobile application
- Material lifting demonstrated on a working prototype
- A basis for evaluating indoor transfer workflows
Warehouse material handling
Compact material movement for warehouses, dark stores, and indoor fulfillment facilities.
SLAB is being developed to reduce repetitive manual transfers between storage, packing, and other designated stations.
The current prototype demonstrates remotely operated movement and lifting. The next version targets a 20 kg payload and approximately 1,200 mm lifting reach, subject to physical testing.
Choose a view, or enlarge an image for a closer look.
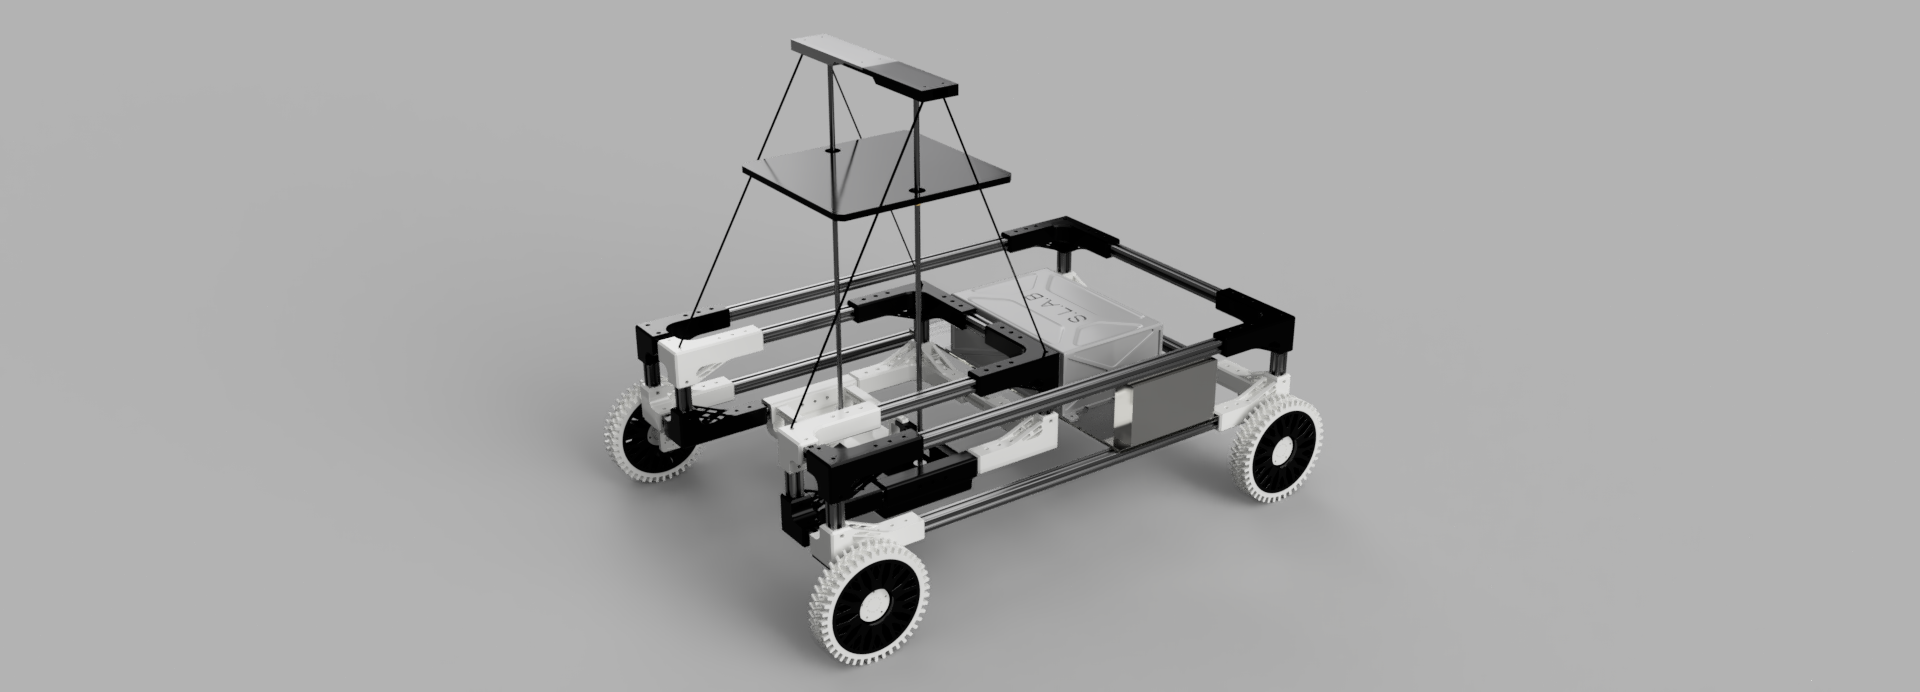
An illustration of the planned material-transfer workflow: collect, move, and deliver.
This illustrates the intended workflow; it is not a live robot feed or a demonstration of autonomous V1 operation.
SLAB is a research and development initiative. V1 is remotely operated and is not ready for production deployment. V2 payload, reach, handling, and navigation goals remain subject to engineering validation and physical testing.
Project inquiry
Share your payload, container sizes, aisle space, lifting needs, and timeline so we can assess the fit.
contact@aetheronlabs.in